Vansh Garg

I am a robotics and computer vision researcher. I am currently a master’s student at the RRC (Robotics Research Center), IIIT-Hyderabad, where I am extremely fortunate to be advised by Prof. K Madhava Krishna. I have also had the pleasure of being guided by some amazing mentors like Sourav Garg and Siddharth Tourani.
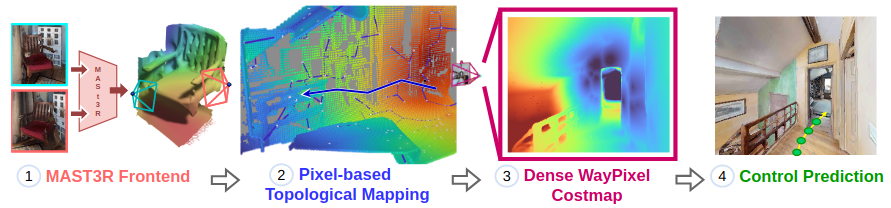
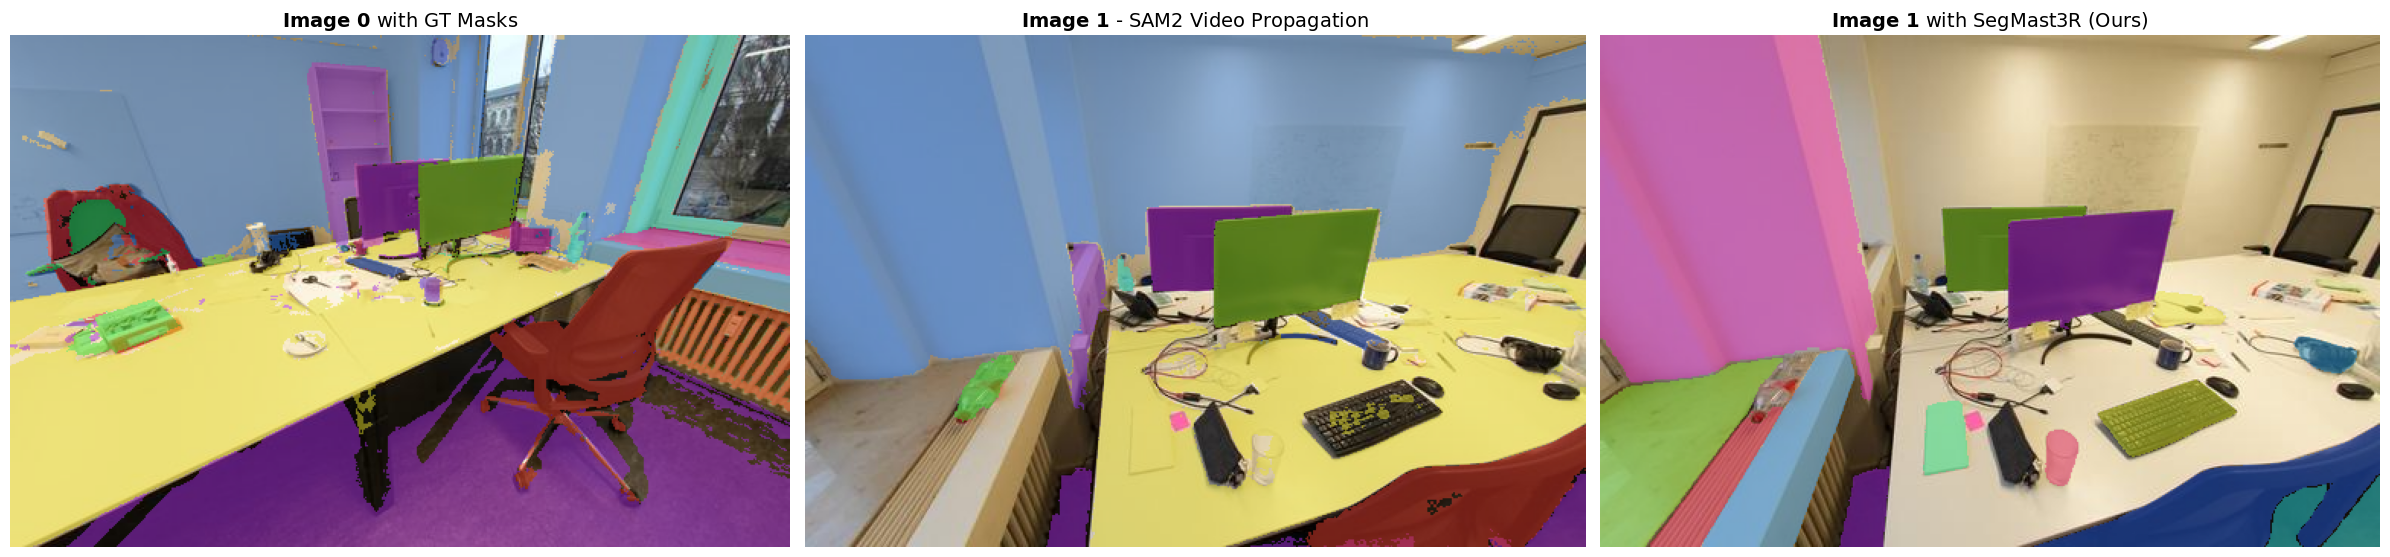
My current research interests lie at the intersection of computer vision and robotics, specifically on improving the spatial and scene understanding of current vision models by grounding them in 3D geometry. I am interested in leveraging geometric priors and 3D-aware representations to improve robustness of these vision models. Recently, these ideas were reflected by our work on improving segment matching and navigation by utilizing the geometric priors of 3D foundation models like MASt3R
When I am not doing research, I usually like to listen to music, go running, or learn guitar. I love receiving emails and messages, so feel free to reach out to me if you have any questions or want to talk about anything related to research or otherwise.
news
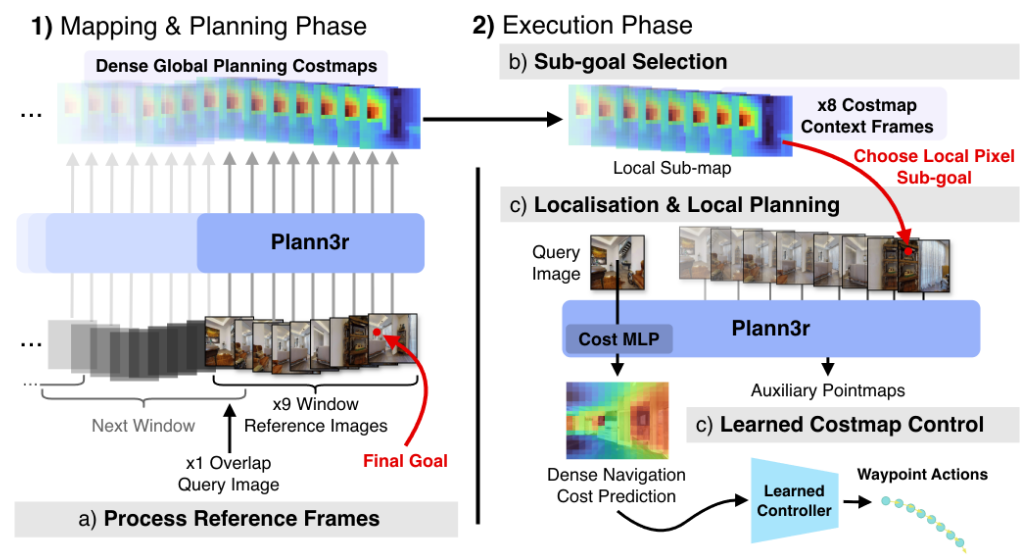
| Sep 04, 2026 | Our work on predicting 3D-grounded planning costs for robot navigation, Plann3r, was accepted to CoRL 2026! 🎉 Krish and Aditya will be presentin the work in Austin this November!!! |
|---|---|
| Sep 04, 2026 | I served as a reviewer for the Conference on Robot Learning (CoRL) 2026. |
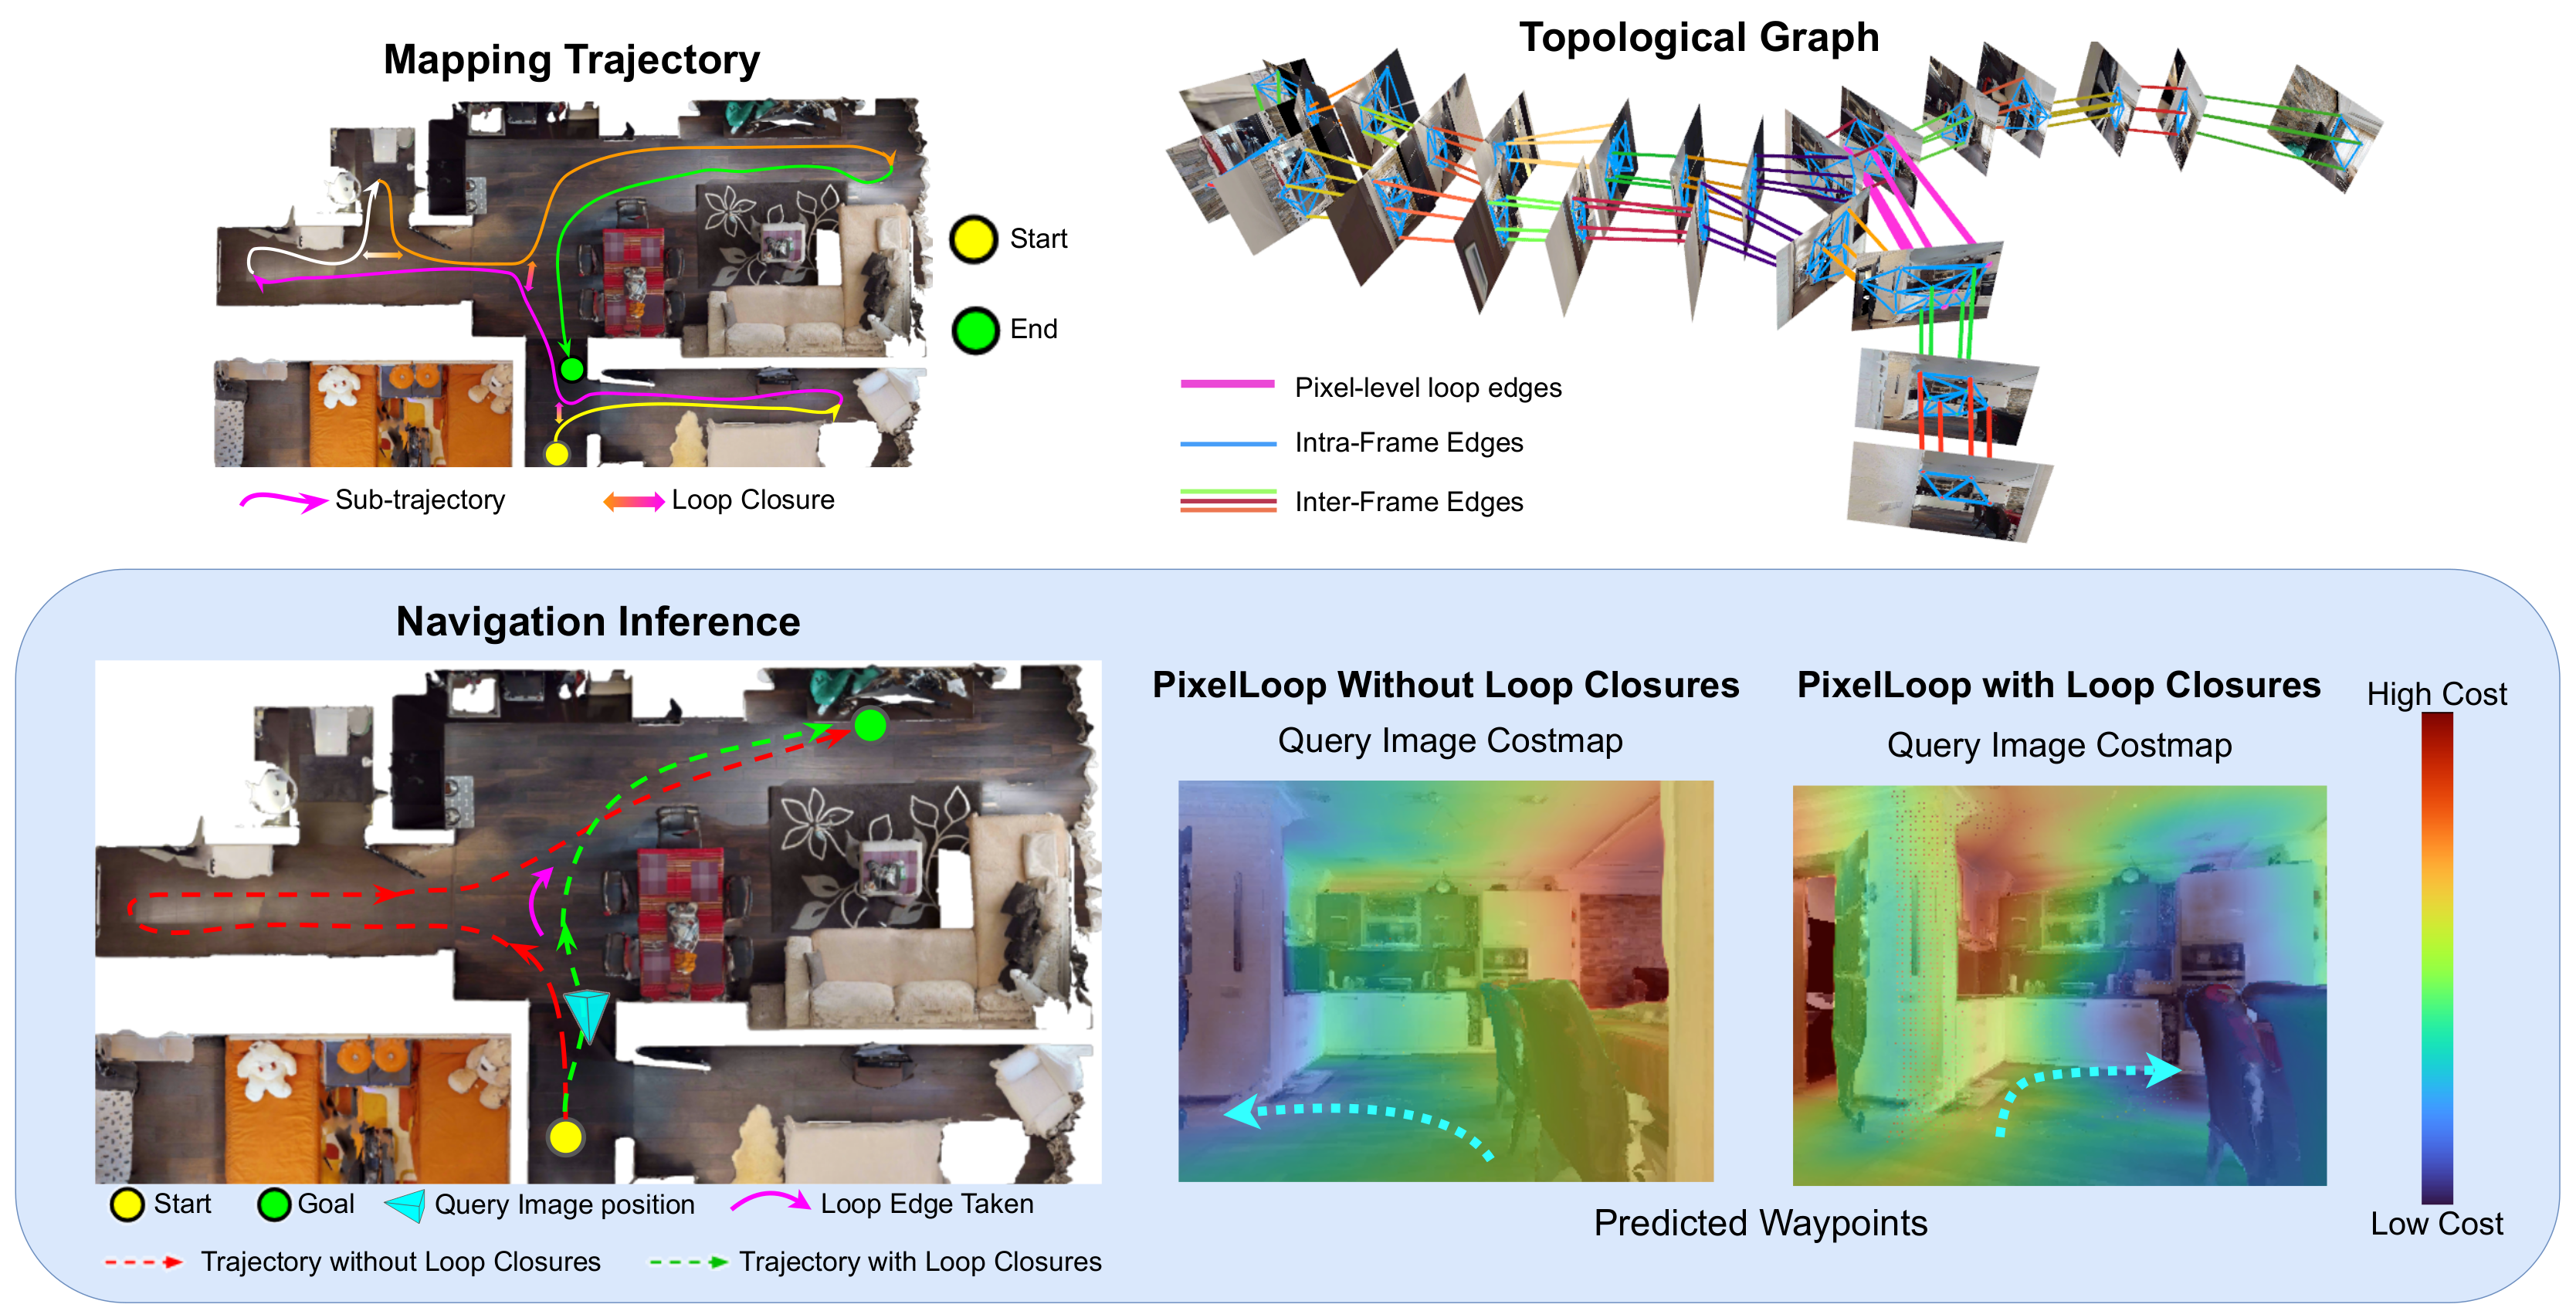
| Jun 16, 2026 | Our work on pixel-level loop closures for topological navigation, PixelLoop, was accepted to IROS 2026! 🎉 See you in Pittsburgh this September! |
| Jan 31, 2026 | Our work on pixel-relative 3D maps for visual navigation, MASt3R-Nav, was accepted to ICRA 2026! 🎉 See you in Vienna this June! |
| Sep 18, 2025 | Our work on geometry-grounded segment matching was accepted to NeurIPS 2025 as a spotlight! 🎉 See you in San Diego this December! |
publications
- ICRA